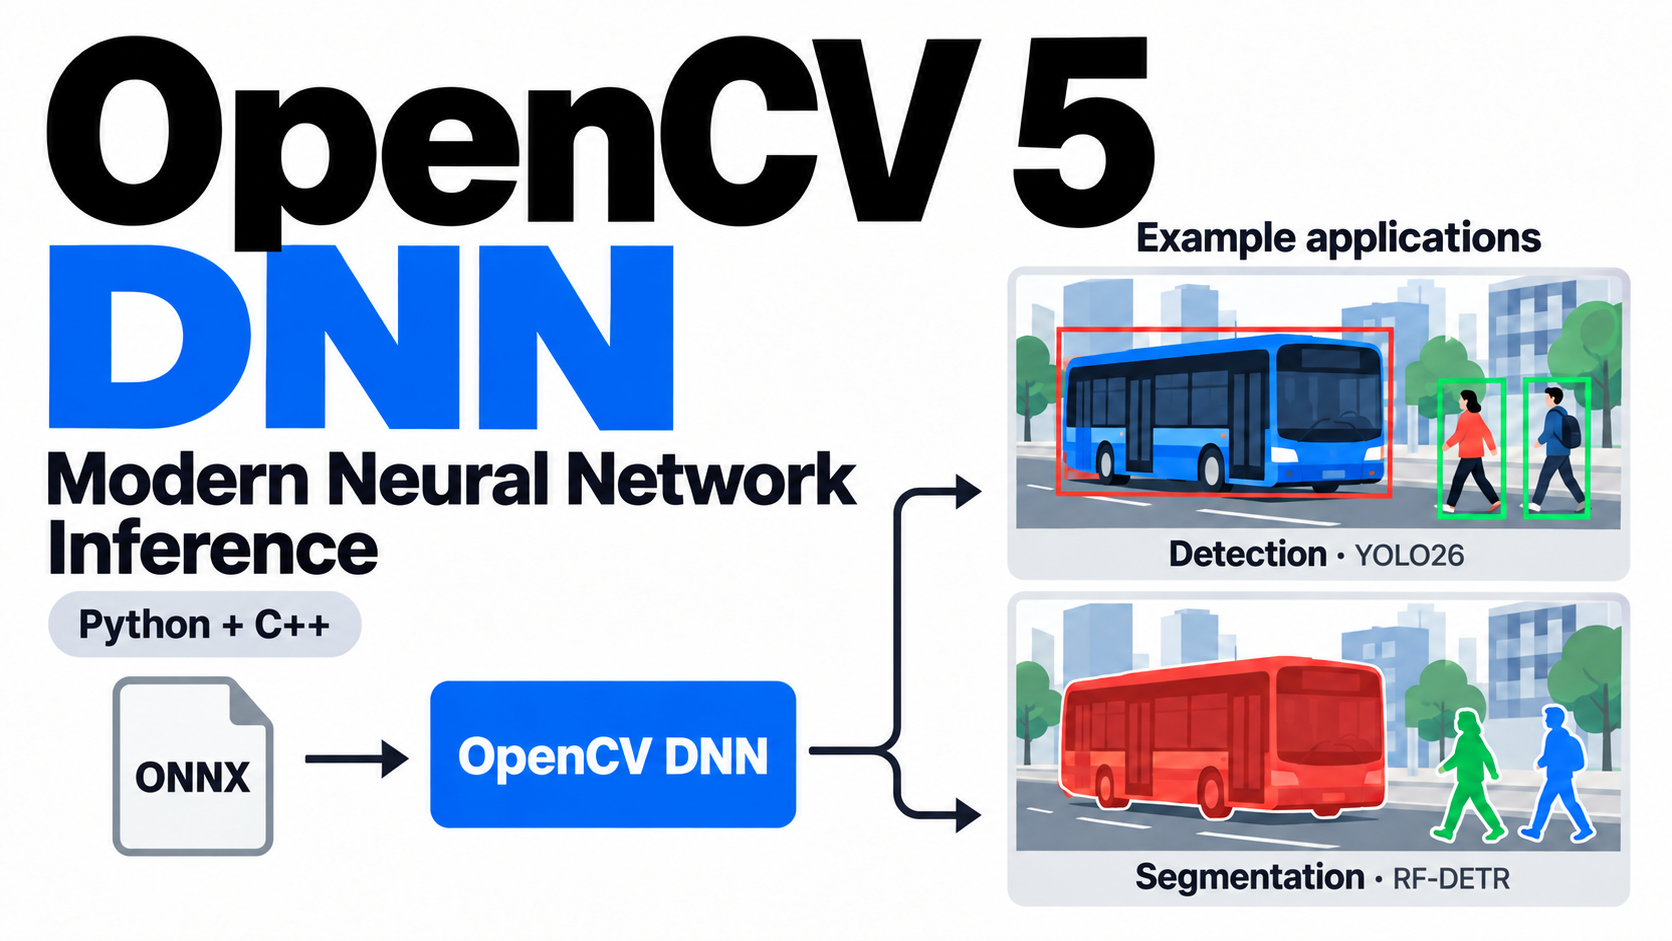
Run YOLO26 detection and RF-DETR instance segmentation with OpenCV 5. Follow tested Python and C++ examples, ONNX export steps, and real output images.
Planned work will focus on native builds, sustainable build-and-test infrastructure, and performance optimization for the open-source developer community PALO ALTO, Calif., Sept. 14, 2026 — The Open Source Vision Foundation
Pengyuan Li of IBM Research returns to OpenCV Live, following his August 2025 appearance where he introduced Granite Vision, IBM’s lightweight open vision-language model built for enterprise document understanding. This
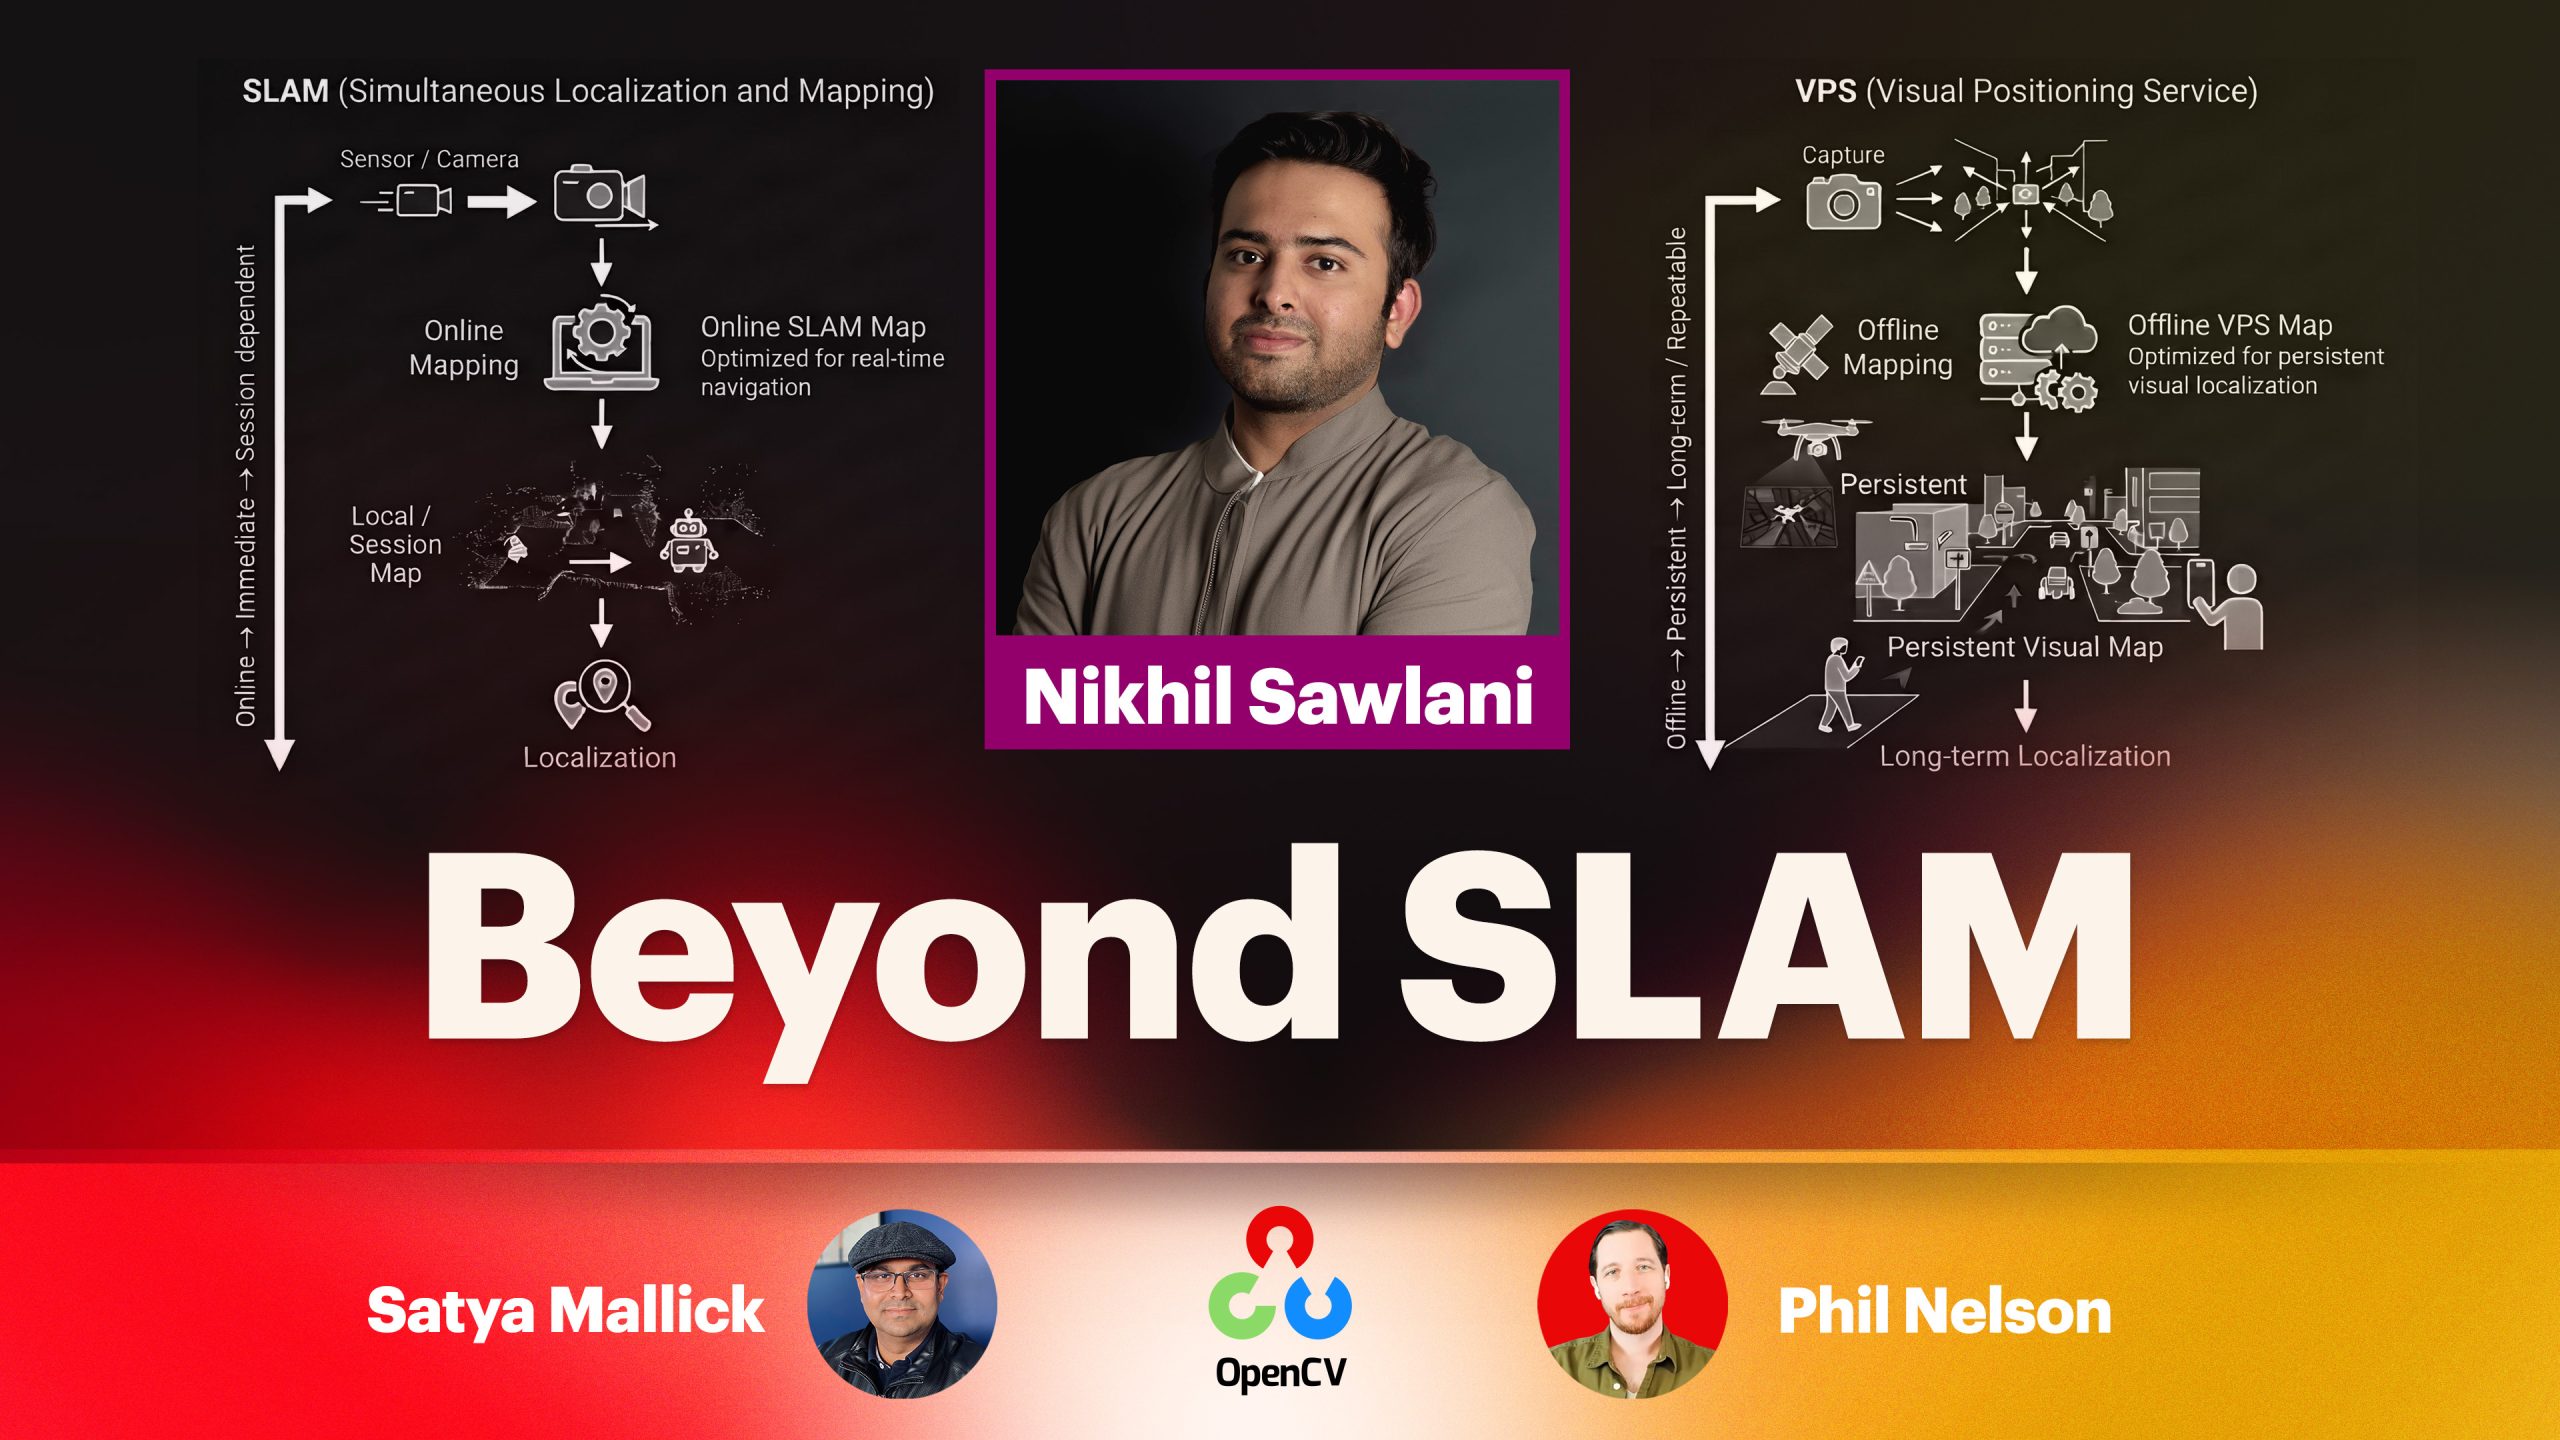
The goal behind this session is to explain to developers how Visual SLAM maps differ from VPS maps, and how to approach challenges such as short-term and long-term relocalization. We
Camera calibration is a familiar pain to anyone who works with computer vision. It can be hard to know where to start, and even difficult to know when you’re “done.”
The 3D-Object Perception Transformer (3PT) unifies detection, segmentation, and 6DoF pose estimation into two multi-view, RGB-only transformers. Demonstrating exceptional accuracy and cross-domain robustness, it placed first by significant margins in
This week join Jason Ren of Ai2 (Allen Institute for AI) for MolmoMotion: Forecasting Point Trajectories in 3D with Language Instruction, a live look at how open multimodal models move
Global computer vision challenge opens to developers, researchers, and teams worldwide with prizes totaling $12,000 [Palo Alto, CA] — The Open Source Vision Foundation (OpenCV), home to the world’s most
Air cargo still runs on estimates — dimensions eyeballed at acceptance, and containers packed by “feel.” Suraj Nair, founder of Singapore-based Speedcargo, joins OpenCV Live to show how 3D computer
One robot is a demo; a hundred robots is an operations problem. Civ Robotics CTO Amit Moran walks through the software practices that keep a distributed rover fleet alive in
Join us this week for a presentation titled “Building the Next Generation of Synthetic Media,” where CraftStory’s Victor Erukhimov shows us how generative AI is reshaping the way digital humans